Offboard Control
WARNING
Offboard control is dangerous. It is the responsibility of the developer to ensure adequate preparation, testing and safety precautions are taken before offboard flights.
The idea behind off-board control is to be able to control the PX4 flight stack using software running outside of the autopilot. This is done through the MAVLink protocol, specifically the SET_POSITION_TARGET_LOCAL_NED and the SET_ATTITUDE_TARGET messages.
Offboard Control Firmware Setup
There are two things you want to setup on the firmware side before starting offboard development.
Map an RC switch to offboard mode activation
To do this, load up the parameters in QGroundControl and look for the RC_MAP_OFFB_SW parameter to which you can assign the RC channel you want to use to activate offboard mode. It can be useful to map things in such a way that when you fall out of offboard mode you go into position control.
Although this step isn't mandatory since you can activate offboard mode using a MAVLink message. We consider this method much safer.
Enable the companion computer interface
Enable MAVLink on the serial port that you connect to the companion computer (see Companion Computers).
Hardware setup
Usually, there are three ways of setting up offboard communication.
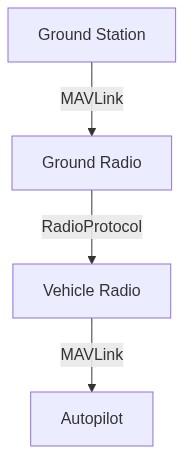
Serial radios
One connected to a UART port of the autopilot
One connected to a ground station computer
Example radios include:
On-board processor
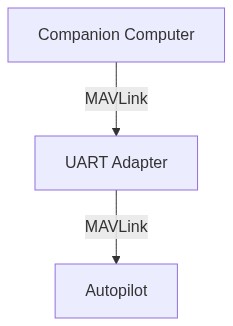
A small computer mounted onto the vehicle, connected to the autopilot through a serial port or Ehthernet port. There are many possibilities here and it will depend on what kind of additional on-board processing you want to do in addition to sending commands to the autopilot. Some examples are provided in Companion Computers.
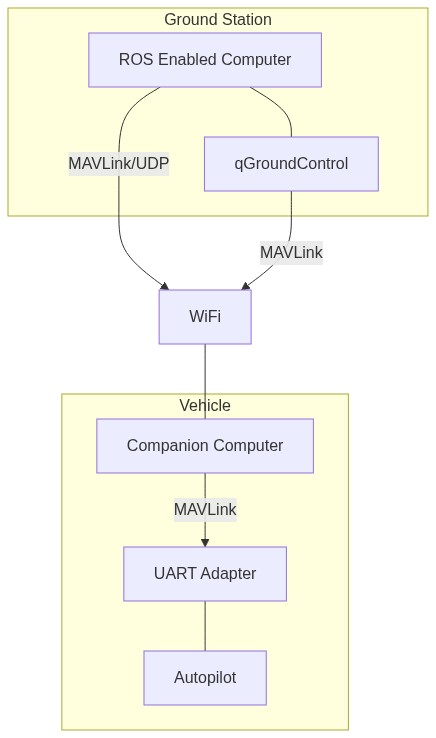
On-board processor and wifi link to ROS (Recommended)
A small computer mounted onto the vehicle connected to the autopilot through a UART to USB adapter while also having a WiFi link to a ground station running ROS. This can be any of the computers from the above section coupled with a WiFi adapter.