
고정익 트리밍 가이드
트림은 트림 조건 (상대적 속도, 공기 밀도, 공격 각도, 항공기 구성 등)에서 제어 표면을 보정합니다. 트림 조건에서 적절하게 트림된 항공기는 조종사 또는 안정화 컴퓨터의 제어 입력 없이도 안정된 자세를 유지할 수 있습니다.
General aviation, commercial and large unmanned planes trim their control surfaces using trim tabs while small UAVs simply add an offset to the actuator of the control surface.
The Basic trimming section explains the purpose of each trim parameter and how to find the correct value. The Advanced Trimming section introduces parameters that can be set to automatically adjust the trims based on the measured airspeed and flap position.
기본 트리밍
고정익을 적절히 트림하기 위해 사용할 수있는 매개변수가 있습니다. 트리밍 매개변수의 사용 사례에 대한 개요는 다음과 같습니다.
- RCx_TRIM applies trim to the signal received from the RC transmitter. These parameters are set automatically during RC calibration.
- CA_SV_CSx_TRIM applies trim to a control surfaces channel. 이들은 비행 전에 제어 표면을 기본 각도로 미세하게 정렬하는 데 사용됩니다.
- FW_PSP_OFF is the pitch angle at which your aircraft flies level at trim airspeed. See Level-Flight Pitch for how PX4 defines and uses it.
- FW_AIRSPD_TRIM is used by the rate controllers to scale their output depending on the measured airspeed. See Airspeed Scaling for more details.
- TRIM_ROLL, TRIM_PITCH and TRIM_YAW apply trim to the control signals before mixing. For example, if you have two servos for the elevator,
TRIM_PITCHapplies trim to both of them. 조종면이 정렬되어 있지만 수동 (안정화되지 않은) 비행 중에 기체가 피치/롤/요잉 업/다운/왼쪽/오른쪽 또는 안정된 비행 중에 제어 신호에 일정한 오프셋이 있는 경우에 사용됩니다.
위의 매개 변수를 설정하는 올바른 순서는 다음과 같습니다.
- Trim the servos by physically adjusting the linkages lengths if possible and fine tune by trimming the PWM channels (use
PWM_MAIN/AUX_TRIMx) on the bench to properly set the control surfaces to their theoretical position. - Fly in stabilized mode at cruise speed and set
FW_PSP_OFFto the pitch angle that the airplane needs to fly at in order to keep constant altitude during wing-leveled flight. If you are using an airspeed sensor, also set the correct cruise airspeed (FW_AIRSPD_TRIM). - Look at the actuator controls in the log file (upload it to Flight Review and check the Actuator Controls plot for example) and set the pitch trim (
TRIM_PITCH). 이 값을 수평 비행 중의 피치 신호의 평균 오프셋으로 설정합니다.
로그 조회가 필요가 없거나 수동 모드에서 편안하게 비행 할 수있는 경우 2 단계 전에 3 단계를 수행할 수 있습니다. You can then trim your remote (with the trim switches) and report the values to TRIM_PITCH (and remove the trims from your transmitter) or update TRIM_PITCH directly during flight via telemetry and QGC.
Level-Flight Pitch
PX4 measures the fixed-wing pitch angle θ between the body x-axis and the horizon. The body frame is fixed to the vehicle: x points forward through the nose, y along the right wing and z down. Its orientation follows the mounting of the flight controller (see Flight Controller Orientation), not the wing chord. For tailsitters, the fixed-wing body frame is the multicopter body frame rotated by 90° in pitch.
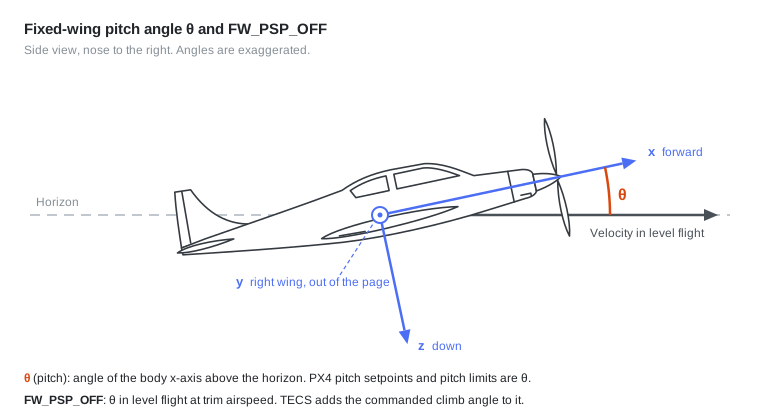
FW_PSP_OFF is θ in level flight at trim airspeed (FW_AIRSPD_TRIM). In level flight the velocity is horizontal, so this is also the angle of attack measured from the body x-axis. It differs from the angle of attack of the wing by the angle between the wing chord and the body x-axis.
Pitch setpoints and pitch limits in PX4 are absolute pitch angles θ, and FW_PSP_OFF is not added to them. This applies for example to FW_P_LIM_MIN, FW_P_LIM_MAX, FW_TKO_PITCH_MIN, FW_LND_FL_PMIN, FW_LND_FL_PMAX and RWTO_PSP.
FW_PSP_OFF itself is used in these places:
- The altitude and airspeed controller (TECS) uses
FW_PSP_OFFas the pitch at zero climb angle: its pitch setpoint isFW_PSP_OFFplus the commanded climb angle plus an integrator correction. The logged TECS pitch setpoint (tecs_status.pitch_sp_rad) is absolute, while the logged pitch integrator (tecs_status.pitch_integ) is a correction added to it rather than a pitch angle. - In Stabilized mode, the centred pitch stick commands
FW_PSP_OFF. - During the front transition, standard VTOLs ramp their pitch setpoint to
FW_PSP_OFF, and tailsitters end their pitch-down rotation at it. - The first principle check of the airspeed validation considers the vehicle to be pitching down when θ is below
FW_PSP_OFF.
고급 트리밍
비대칭 익형에 의해 유도된 하향 피치 모멘트는 대기 속도에 따라 증가하고 플랩이 전개 될 때 현재 측정된 대기 속도와 플랩 위치에 따라 항공기를 다시 트리밍하여야 합니다. For this purpose, a bilinear curve function of airspeed and a pitch trim increment function of the flaps state (see figure below) can be defined using the following parameters:
- FW_DTRIM_[R/P/Y]_[VMIN/VMAX] are the roll/pitch/yaw trim value added to
TRIM_ROLL/PITCH/YAWat min/max airspeed (defined by FW_AIRSPD_MIN and FW_AIRSPD_MAX). - CA_SV_CSx_FLAP and CA_SV_CSx_SPOIL are the trimming values that are applied to these control surfaces if the flaps or the spoilers are fully deployed, respectively.
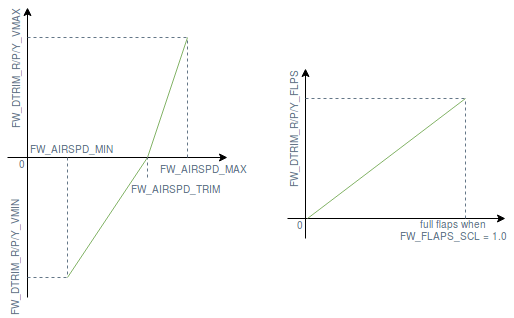
A perfectly symmetrical airframe would only require pitch trim increments, but since a real airframe is never perfectly symmetrical, roll and yaw trims increments are also sometimes required.