
조이스틱 설정
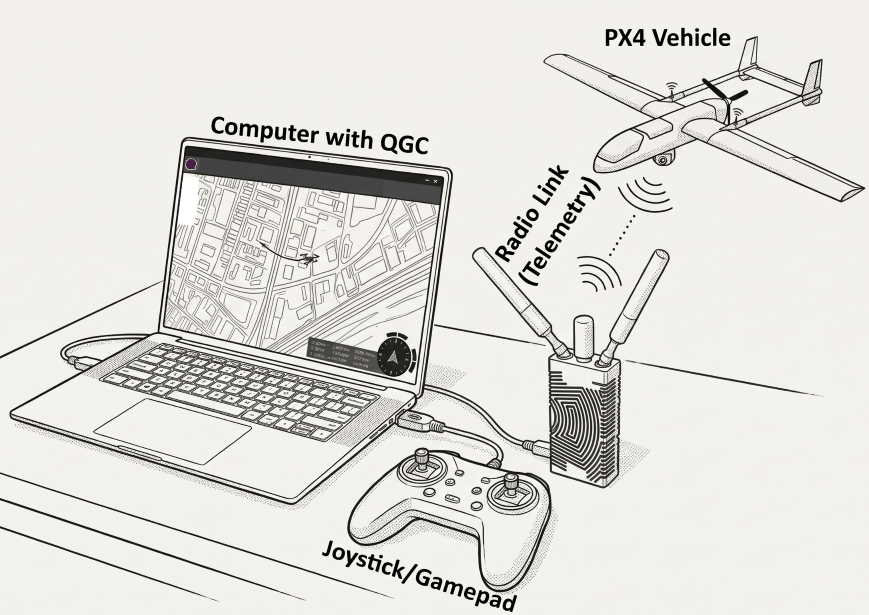
A computer joystick or gamepad connected to a device running QGroundControl (QGC) can be used to manually control a vehicle (instead/as well as an RC Transmitter)
This approach sends Joystick movements and button presses encoded as MAVLink MANUAL_CONTROL messages over the telemetry link, which provides a simpler and (usually) less expensive setup than using a separate RC Transmitter.
Joysticks are often used in Integrated Ground Control Stations and are recommended for flying the vehicle in simulation.
TIP
A joystick-based controller system requires a reliable, high-bandwidth telemetry link to ensure that the vehicle is responsive to joystick movements. RC Transmitters are preferred for vehicle bring-up and in other situations where very low latency is required.
PX4 조이스틱 지원 활성화
Information about how to set up a joystick is covered in: QGroundControl > Joystick Setup.
TIP
Radio Setup is not required when using only a joystick.
참고:
- If you have multiple Joysticks and/or also have an RC Controller, set COM_RC_IN_MODE as described in Manual Control > PX4 Configuration.
- Manual control and telemetry share one link so you should set Manual Control Loss and Data Link Loss failsafe actions consistently.
개발자 정보
QGC uses the cross-platform SDL library to convert joystick movements to MAVLink MANUAL_CONTROL messages, which are then sent to PX4 over the telemetry link. PX4 also defines fixed meanings to some of the MANUAL_CONTROL button values, and these are mapped to user-selected functions by the ground station.
Other ground stations and MAVLink APIs may use different methods to map joystick controls to MANUAL_CONTROL messages.