
Датчики швидкості польоту
Airspeed sensors are highly recommended for fixed-wing and VTOL frames. Це важливо, туму що автопілот не має інших засобів для виявлення звалювання. Так як швидкість польоту літака відносно повітря гарантує підіймальну силу, а не швидкість відносно землі!
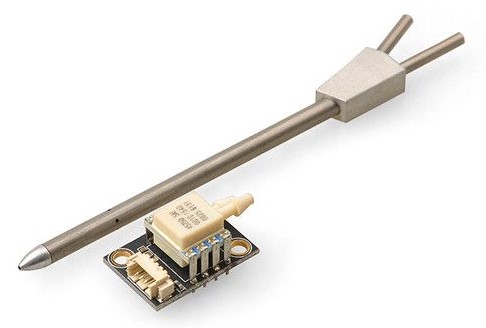
Варіанти устаткування
Рекомендовані цифрові сенсори швидкості в повітрі включають:
- Based on Pitot tube
- I2C MEAS Spec series (e.g. MS4525DO, MS5525)
- I2C Sensirion series (e.g. SDP33)
- I2C Amphenol All Sensors Digital Low Voltage R-Series (DLVR) Pressure Sensors. Continuous-sampling sensors only (see for SENS_EN_DLVR for supported sensors).
- DroneCAN interface
- Based on Venturi effect
- TFSLOT Venturi effect airspeed sensor.
Налаштування
Увімкнення датчиків швидкості у повітрі
Драйвери датчика швидкості в польоті не запускаються автоматично. Enable each driver and/or variant using its corresponding parameter:
- Sensirion SDP3X — SENS_EN_SDP3X
- TE MS4525 — SENS_EN_MS4525DO
- TE MS5525 — SENS_EN_MS5525DS
- Eagle Tree airspeed sensor: — SENS_EN_ETSASPD
- Amphenol All Sensors DLVR (continuous-sampling sensors only) — SENS_EN_DLVR
You should also check ASPD_PRIMARY is 1 (see next section - this is the default).
Множинні датчики швидкості польоту
WARNING
Експериментальні налаштування Using multiple airspeed sensors is experimental.
If you have multiple airspeed sensors then you can select which sensor is preferred as the primary source using ASPD_PRIMARY, where 1, 2 and 3 reflect the order in which the airspeed sensors were started:
0: Synthetic airspeed estimation (groundspeed minus windspeed)1: First airspeed sensor started (default)2: Second airspeed sensor started3: Third airspeed sensor started
The airspeed selector validates the indicated sensor first and only falls back to other sensors if the indicated sensor fails airspeed checks (ASPD_DO_CHECKS is used to configure the checks).
The selected sensor is then used to supply data to the estimator (EKF2) and the controllers.
Налаштування датчика
Крім активації датчика, часто не потрібна конфігурація, специфічна для датчика. If it is needed, it should be covered in the appropriate sensor page (for example TFSLOT > Configuration).
Конкретна конфігурація для датчиків, які не мають окремої сторінки, перерахована нижче:
- Sensirion SDP3X: CAL_AIR_CMODEL (provides overview of required settings), CAL_AIR_TUBED_MM, CAL_AIR_TUBELEN.
Калібрування
Airspeed sensors should be calibrated by following the instructions: Basic Configuration > Airspeed.
For more advanced validation, configuration and debugging see Airspeed Validation.